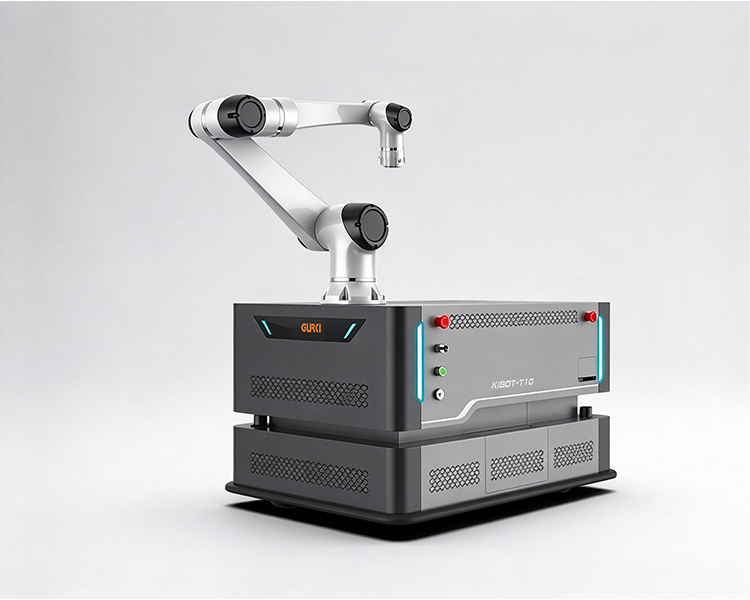
How the product works
Task-Driven Operation:
It defines operation objects, starting stations, target stations and task requirements according to upper system commands or local tasks.
Task & Station Configuration:
It configures operation objects, station positions and handling requirements to provide basic information for robot task execution.
Motion Sequence Arrangement:
It organizes motion sequences such as movement, positioning, picking, transferring, placing and handover based on tasks.
Operation Status Closed-Loop:
It updates the status of tasks, robot and stations in real time, and supports exception recovery and result feedback.
Multi-Robot Task Collaboration:
It performs unified task allocation, resource coordination and traffic control in multi-robot scenarios.